Bridging Control Theory and Aerial Autonomy
Fusing advanced control algorithms (LQR/PID), real-time computer vision, and industrial automation to build resilient, life-conscious autonomous systems.
Electrical-Electronics & Intelligent Systems Engineer
I design and validate autonomous systems end to end — from carbon composite airframes and avionics wiring to flight control laws, onboard perception and industrial PLC/robot cells. My focus: VTOL UAVs, LQR/PID control, state estimation and computer vision.
Hybrid VTOL, from workshop to flight
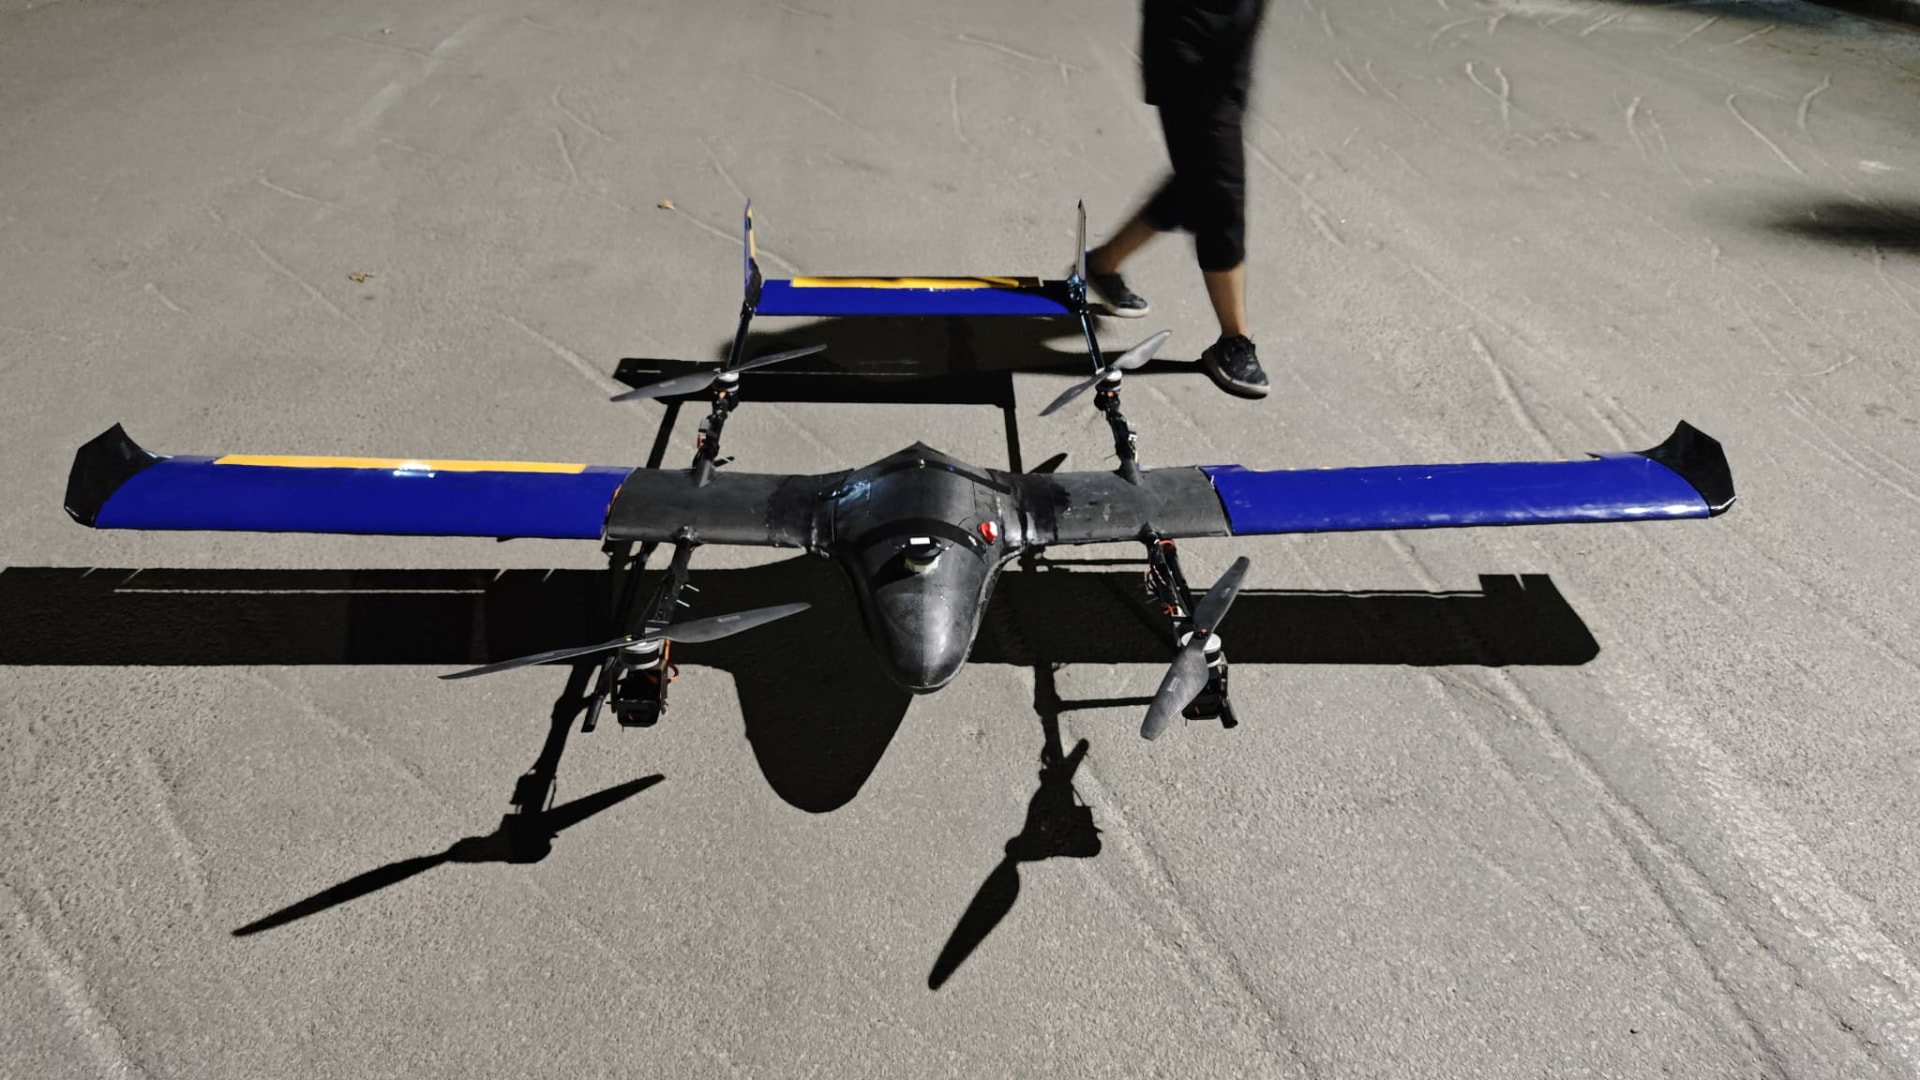

Ansızın T7-24 / TUFAN VTOL UAV
Full-lifecycle design, avionics integration, and autonomous transition flight testing with BTU-ALFA.
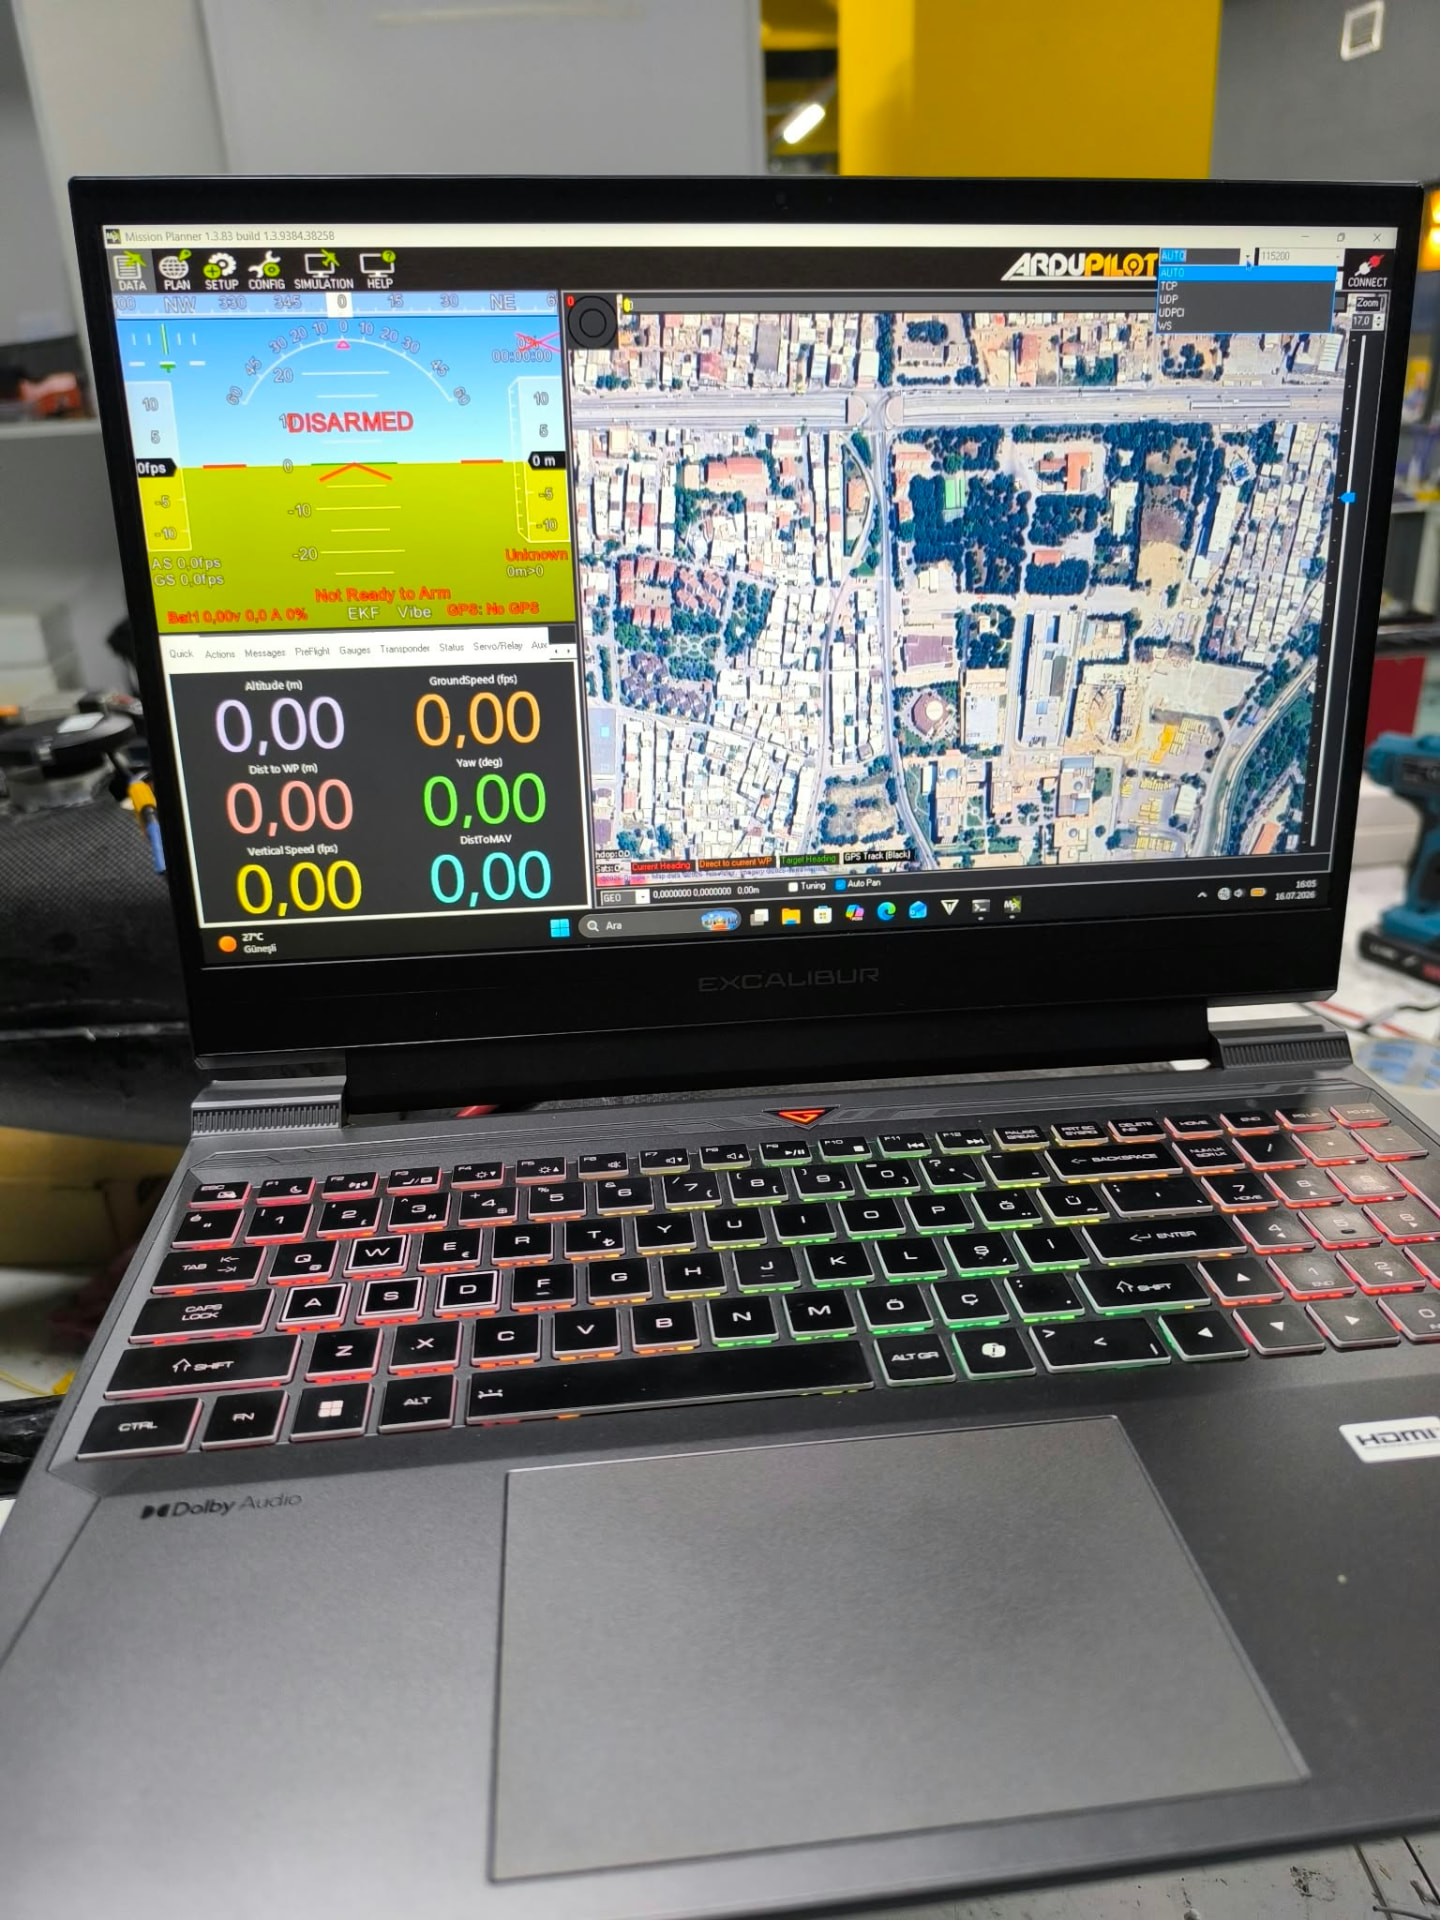
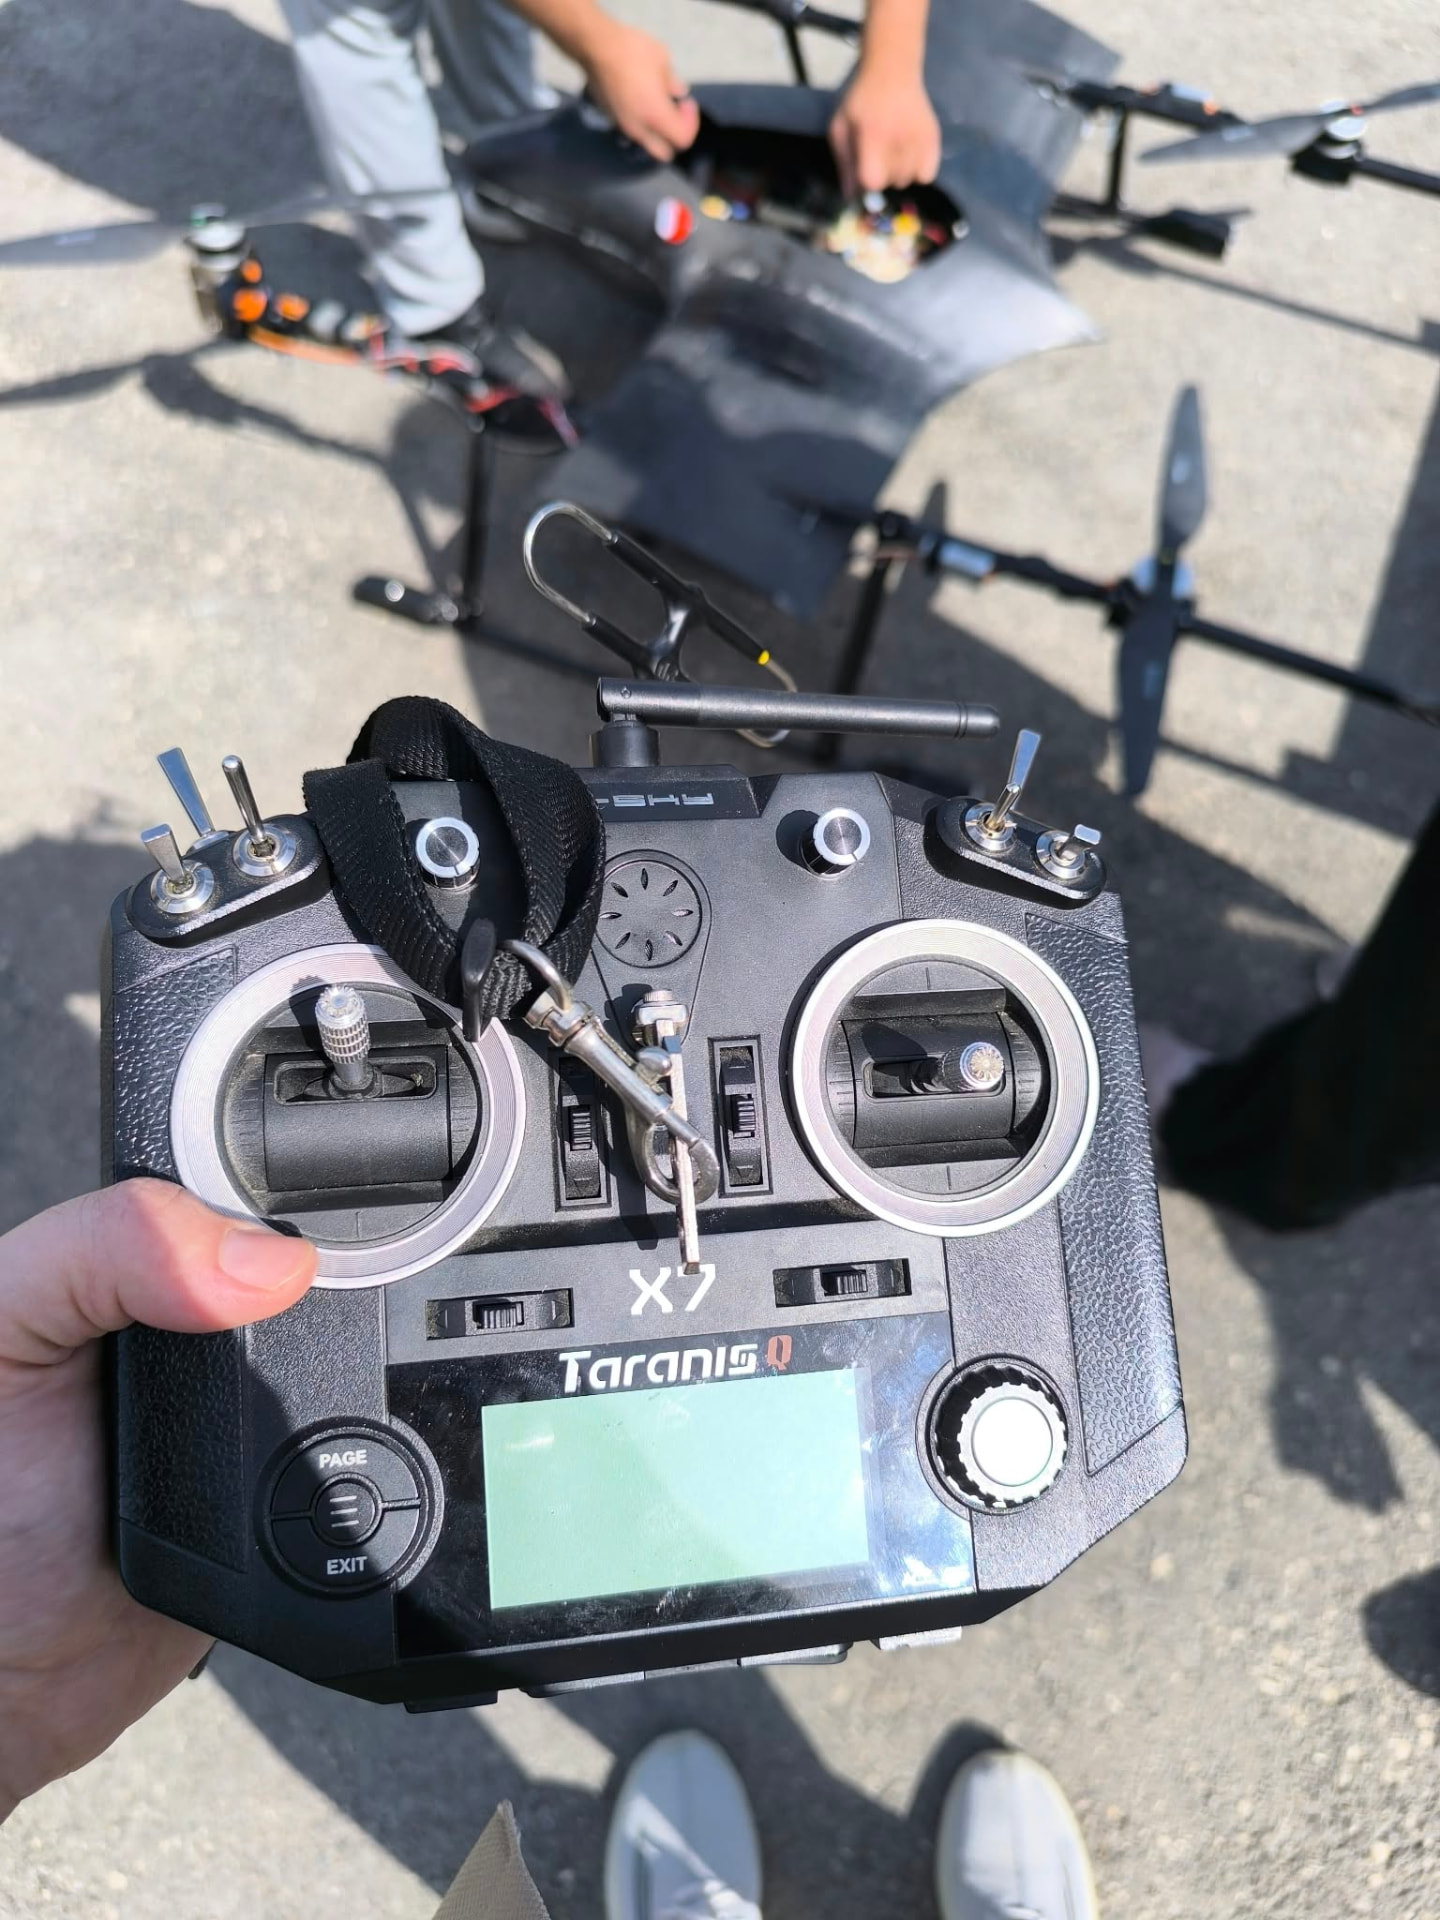
Applied Industrial Automation & Robotics Laboratory
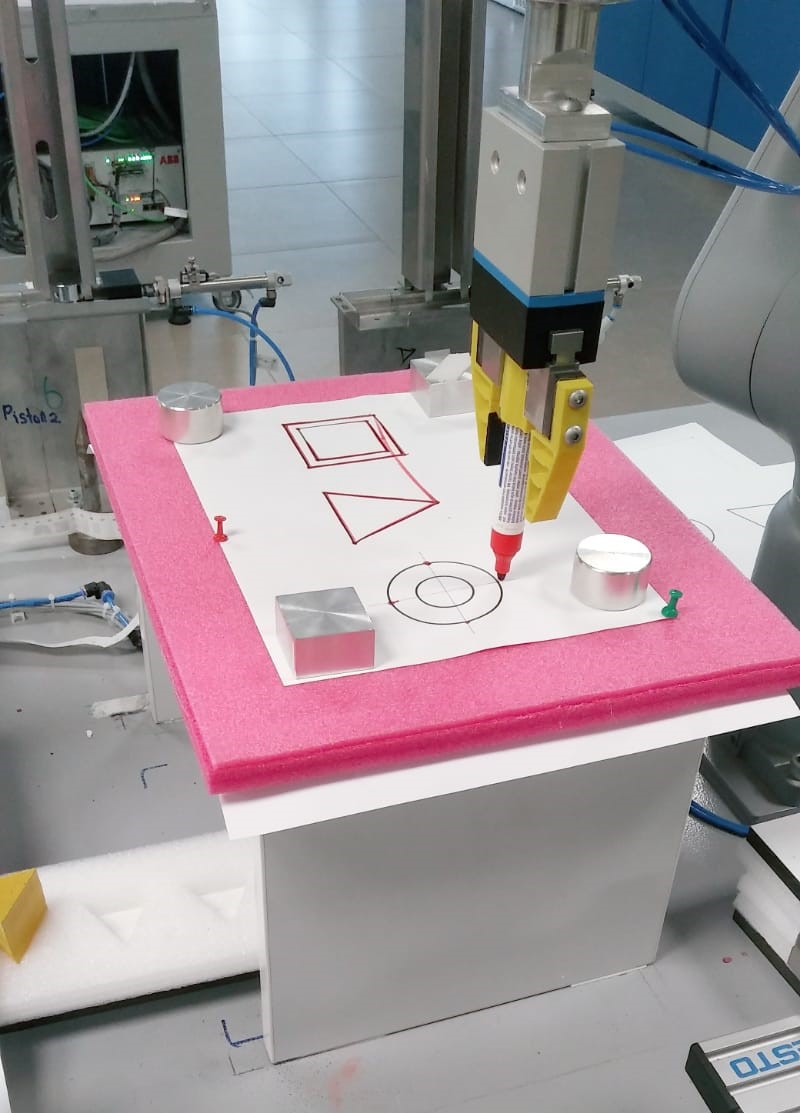
Trajectory Control & RAPID Scripting
Taught geometric trajectories (triangle, circle) on an ABB arm. Arc paths are built from MoveC circular interpolation through via/to targets, verified point-by-point on the FlexPendant.
Speed Estimation from Imagery for VTOL UAVs
Estimating true ground and air velocity vectors in sensor-denied / GPS-degraded environments from downward-looking high-speed camera streams and optical flow.
Timeline
Selected work
Ansızın T7-24 / TUFAN VTOL UAV
Custom airframe flight dynamics, transition controller, and sensor telemetry.
Velocity Estimation via Optical Flow
Real-time downward-facing camera image velocity vector computation.
Autonomous Industrial Robotic Cell
Multi-axis pick-and-place with ABB RobotStudio and PLC synchronization.
Predictive Machine Learning Pipelines
Churn, classification, and statistical modeling using Python and scikit-learn.